Basic BootstrapODPSample

Basic BootstrapODPSample#

import chainladder as cl

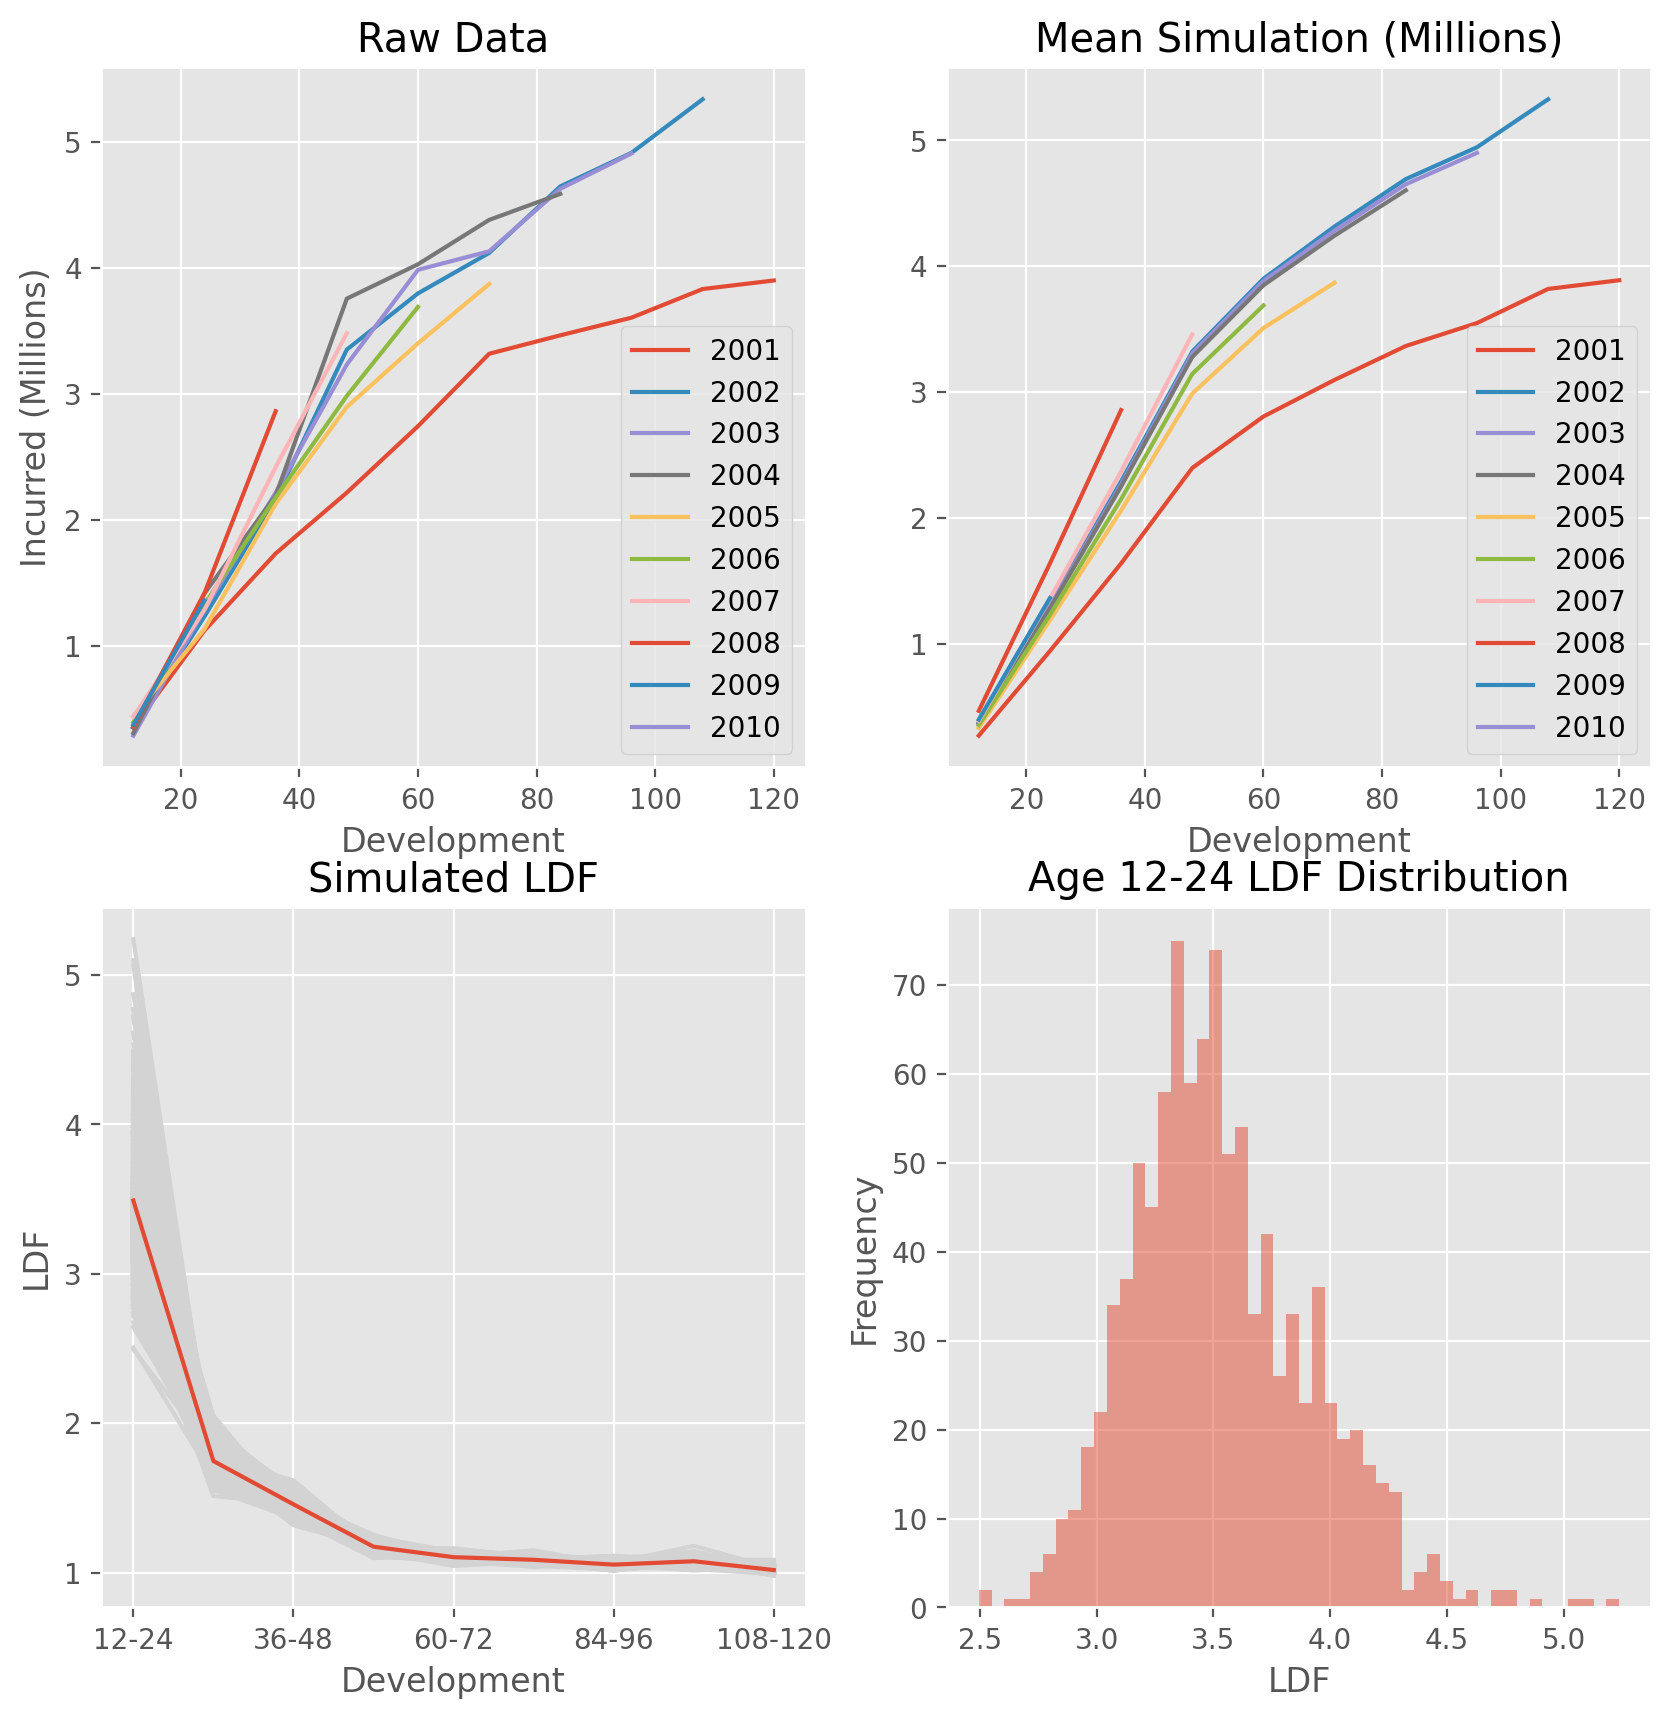
This example demonstrates how you can can use the Overdispersed Poisson Bootstrap sampler and get various properties about parameter uncertainty.

#  Grab a Triangle
tri = cl.load_sample("genins")

# Generate bootstrap samples
sims = cl.BootstrapODPSample(random_state=42).fit_transform(tri)

# Calculate LDF for each simulation
sim_ldf = cl.Development().fit(sims).ldf_

plot1 = tri.T / 1e6
plot2 = (sims.sum() / 1000).T / 1e6
plot3a = sim_ldf.T
plot3b = cl.Development().fit(tri).ldf_.drop_duplicates().T
plot4 = sim_ldf.T.loc["12-24"]
Hide code cell source

import matplotlib.pyplot as plt

plt.style.use("ggplot")
%config InlineBackend.figure_format = 'retina'

# Plot the Data
fig, ((ax00, ax01), (ax10, ax11)) = plt.subplots(ncols=2, nrows=2, figsize=(10, 10))

# Plot 1
plot1.plot(
    ax=ax00, title="Raw Data", xlabel="Development", ylabel="Incurred (Millions)"
)

# Plot 2
plot2.plot(ax=ax01, title="Mean Simulation (Millions)", xlabel="Development")

# Plot 3
plot3a.plot(
    legend=False,
    color="lightgray",
    ax=ax10,
    title="Simulated LDF",
    xlabel="Development",
    ylabel="LDF",
)
plot3b.plot(legend=False, ax=ax10, grid=True)

# Plot 4
plot4.plot(
    kind="hist",
    bins=50,
    alpha=0.5,
    ax=ax11,
    title="Age 12-24 LDF Distribution",
    xlabel="LDF",
);